Driving Prototype
Role
Game Developer
Year
2024
Tools
Unity, C#
Overview
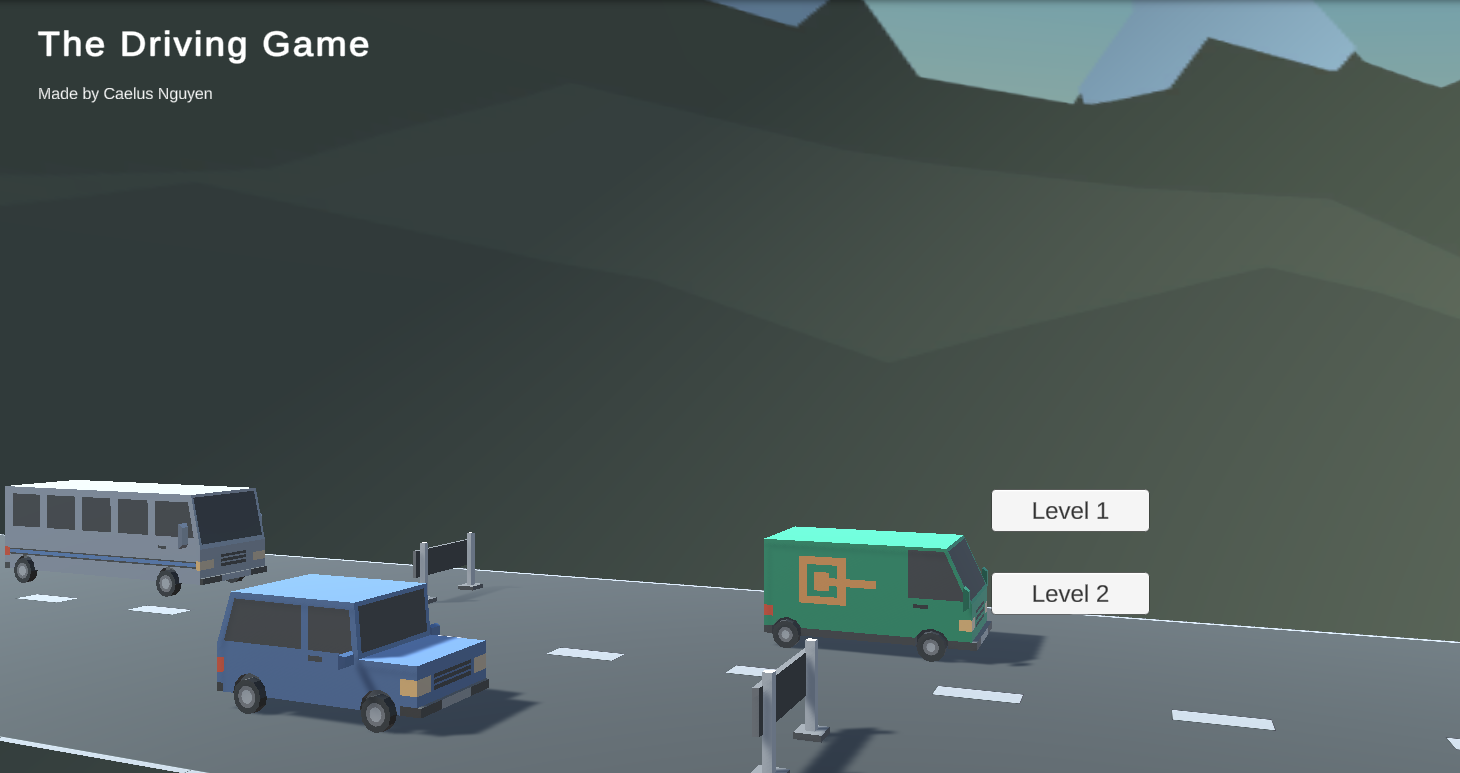
An ongoing Unity prototype exploring vehicle physics and driving mechanics. This work-in-progress project focuses on implementing realistic car controls, physics-based movement, and the foundation for a driving game experience.
Project Details
My Contribution
Game Development, Vehicle Physics, Controller Systems
Duration
Ongoing
Status
Work in Progress
Links
Challenge
The main challenge is creating believable vehicle physics that feel responsive and fun to control while maintaining realistic behavior. I'm working on balancing arcade-style accessibility with simulation-level physics accuracy.
Solution
I'm implementing a custom vehicle controller using Unity's Rigidbody physics system, with separate components for engine power, steering, braking, and suspension. The system allows for fine-tuning of various parameters to achieve the desired driving feel.
Process
Vehicle Controller
Developing a flexible vehicle physics system with customizable parameters for different car types.
Input Handling
Implementing responsive controls that work well with both keyboard and gamepad input.
Physics Tuning
Iteratively adjusting physics parameters to achieve satisfying and realistic driving feel.
Gallery
Outcomes
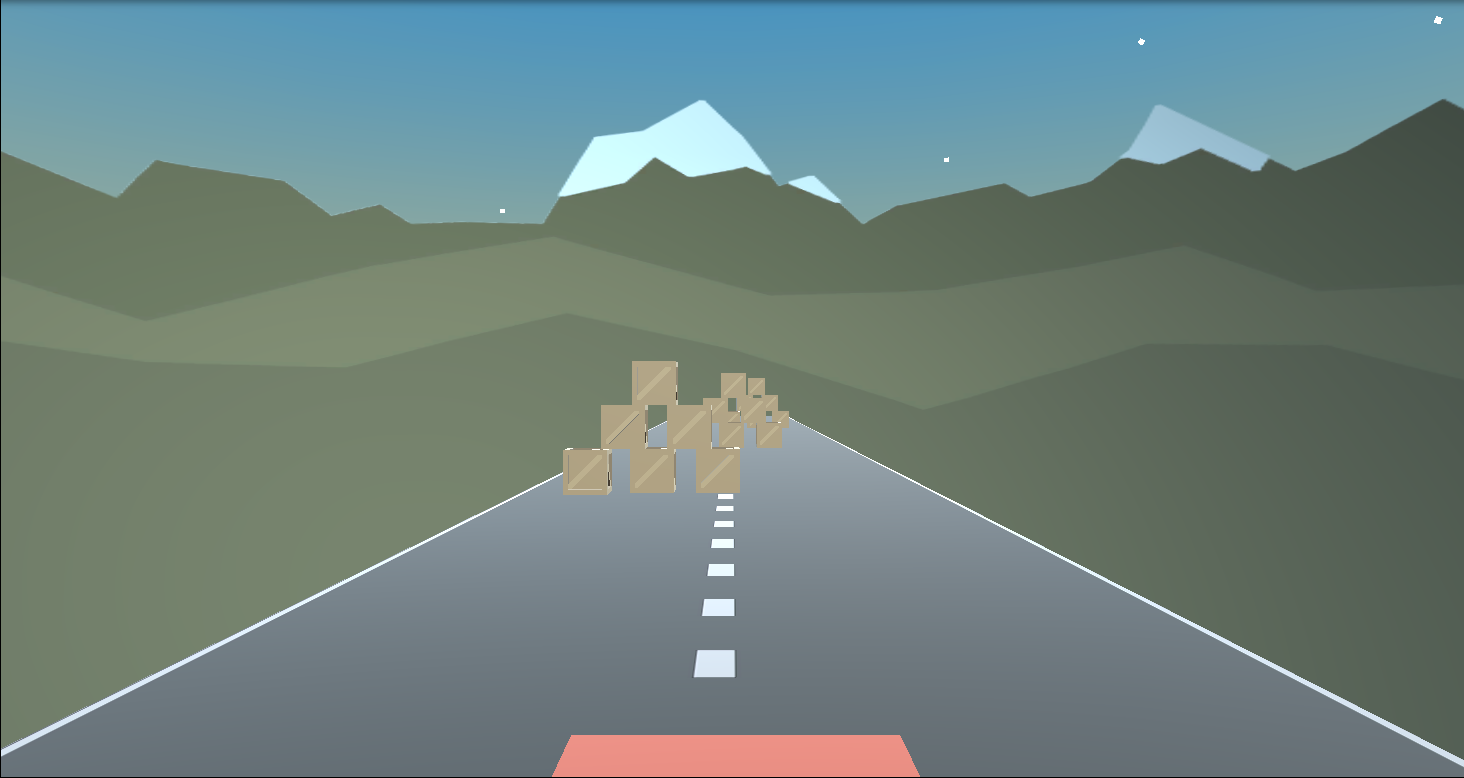
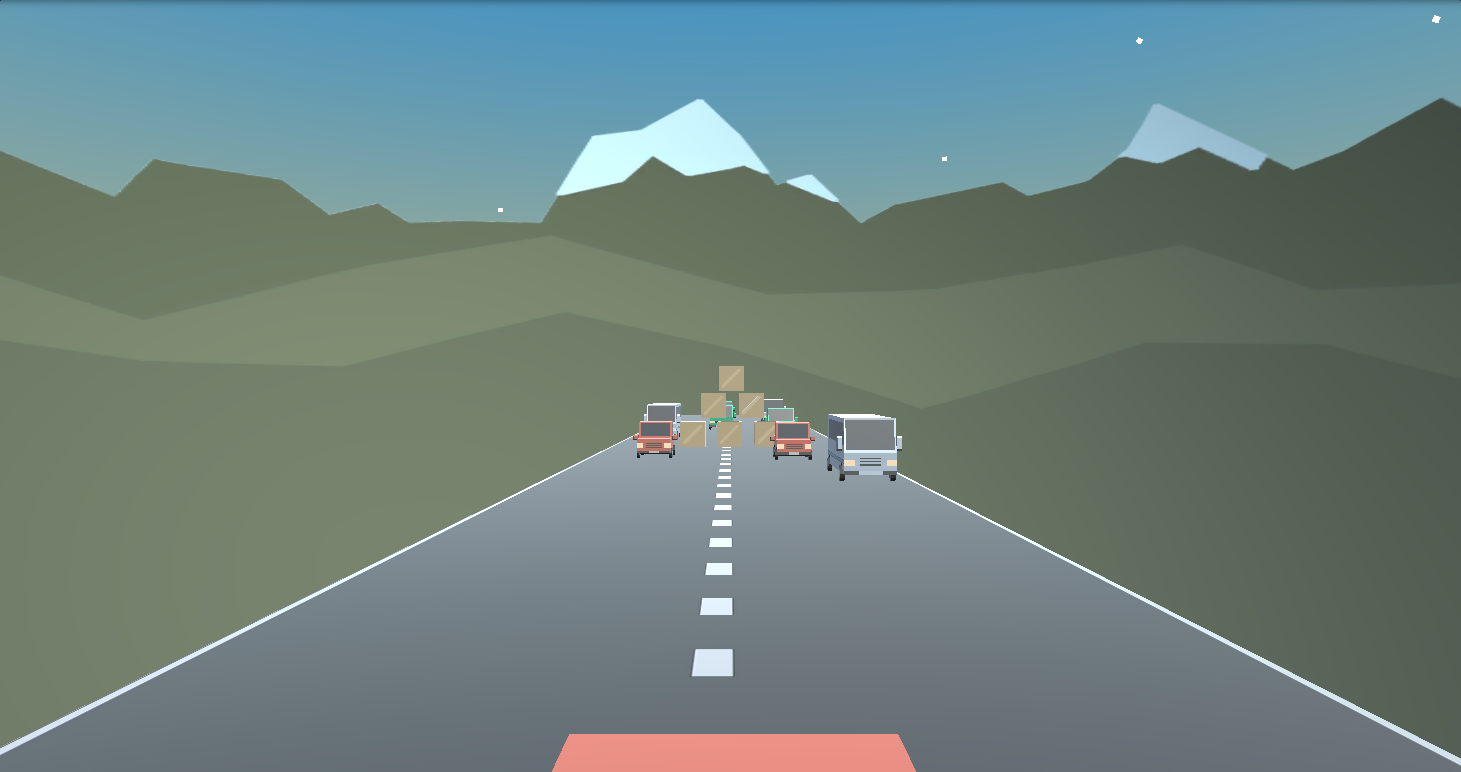
The prototype is still in development, with basic vehicle physics implemented and ongoing refinements to the driving feel. It serves as a learning project for understanding complex physics systems in game development.
Key Results
- Implemented basic vehicle physics with engine, steering, and braking systems
- Created a flexible controller system that can be adapted for different vehicle types
- Established foundation for future driving game development
- Published work-in-progress prototype on Unity Play platform
Lessons Learned
This ongoing project is teaching me about the complexity of vehicle physics simulation and the importance of iterative tuning in creating satisfying game feel. I'm gaining valuable experience with Unity's physics system and learning techniques for creating realistic vehicle behavior.